👋 About Me
I am Weiyi Hu, a senior undergraduate student in Information Engineering at SUSTech advised by Prof. Max Q.-H. Meng, and an incoming Ph.D. student in Control Science and Engineering (Fall 2027) advised by Prof. He Kong. I am currently a research intern at the Shanghai Innovation Institute, working on learning-based whole-body compliance control for robotic manipulation with Prof. Hanbo Zhang.
- Research interests: Embodied AI, learning-based control (manipulation & locomotion), edge intelligence, and computer vision.
- Academics: Overall GPA 3.89/4.0 (Rank 4/48), weighted average 93.78; CET-6 569.
🔥 News
- [2026.10] Our paper REACH (hierarchical humanoid crawling) was accepted by IEEE-RAS Humanoids 2026.
- [2026.09] Admitted to the Ph.D. program in Control Science and Engineering at SUSTech (advisor: Prof. He Kong), starting Fall 2027.
- [2026.06] Joined the Autonomous and Robust Manipulation Group, Shanghai Innovation Institute, as a research intern (Prof. Hanbo Zhang & Prof. Fan Ye).
- [2026.06] My first co-first-authored paper was accepted by IEEE PIMRC 2026 as an oral presentation.
- [2026.06] Our Undergraduate Innovation Training Project was recommended for national-level recognition.
- [2025.12] Received the honorary title of Outstanding Student Model at SUSTech (Top 7 / 5000+).
- [2025.06] Software Engineer Intern at Junhe Water Affairs Co., Ltd.
- [2024.12] As a core member of the Yueran Vision team, received national bronze awards in both the Challenge Cup and the China College Students’ Innovation Competition.
- [2024.09] Joined ACT Lab, SUSTech, advised by Prof. He Kong.
🎓 Education
- [Sep 2027 – Jun 2031 (expected)] Ph.D. in Control Science and Engineering, Southern University of Science and Technology (SUSTech), advisor: Prof. He Kong.
- [Sep 2023 – Jul 2027 (expected)] B.Eng. in Information Engineering, Southern University of Science and Technology (SUSTech), advisor: Prof. Max Q.-H. Meng.
📚 Publications
(* denotes equal contribution, † denotes corresponding author)
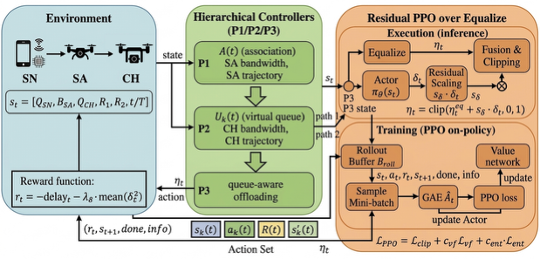
Hierarchical Trajectory and Offloading Optimization for Task Delay Minimization in UAV-Assisted MEC
Ruiyi Yao*, Weiyi Hu*, Leheng Qi, Xiaoyang Li†, Zidong Han, Yi Gong
- Accepted by IEEE PIMRC 2026 (invited oral presentation).
- 📄 Paper PDF
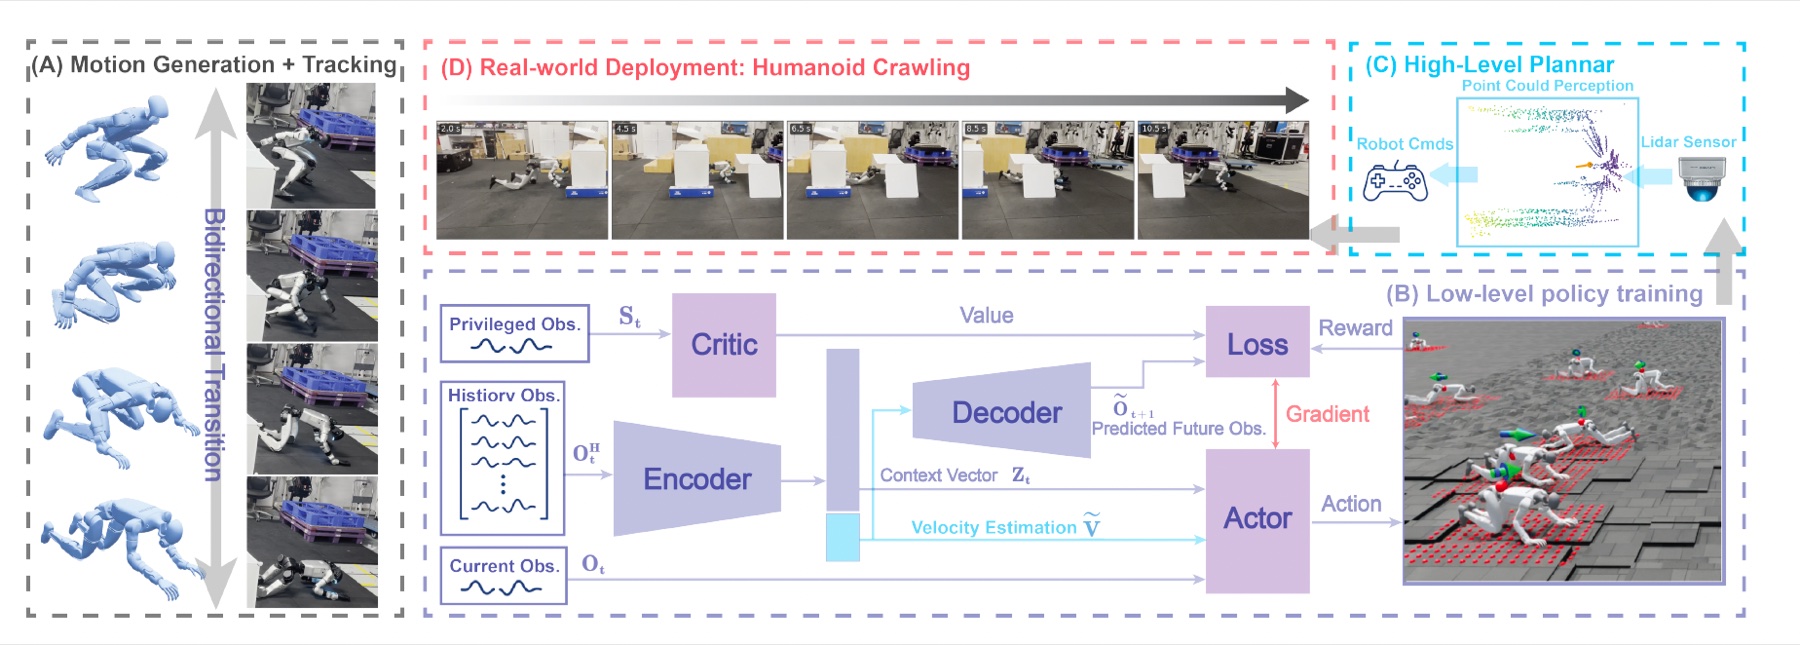
REACH: An RL-based Hierarchical Humanoid Crawling Framework for Scalable Confined Space Traversal
Shengzhang Xu, Yuning Guo, Weiyi Hu, Yifeng Xu, Zhongyu Li, He Kong†
- Accepted by IEEE-RAS International Conference on Humanoid Robots (Humanoids 2026).
- Developed an RL-based hierarchical locomotion framework combining adaptive bipedal walking and quadrupedal crawling for scalable confined-space traversal.
- Validated sim-to-real transfer on the Unitree G1 humanoid robot.
- 📄 paper 🌐 Website
🔬 Research Experience
Autonomous and Robust Manipulation Group, Shanghai Innovation Institute Jun 2026 – Present
- Developed a whole-body compliance controller that augments nominal WBC with physics-based VMC teachers for safe yielding and smooth trajectory recovery under impacts and sustained external pushes.
- Trained an Echo State Network (ESN) to map proprioceptive histories directly to compliance actions, enabling temporally adaptive control and generalization to unseen contact scenarios.
Guangdong Provincial Key Lab of Advanced Wireless Communication Technology Jun 2025 – Jul 2026
- Developed a Lyapunov-guided hierarchical reinforcement learning framework with residual PPO for joint trajectory, offloading, and resource optimization in UAV-assisted MEC, reducing task delay by up to 67.2% [P.1].
Active Intelligent Systems Lab (ACT Lab), SUSTech Sep 2024 – Present
- Developed and deployed a ROS 2/Nav2 perception–planning pipeline on the Unitree G1 humanoid, enabling robust autonomous human following and dynamic obstacle avoidance in real-world experiments. 🔗 Code
- Developed an RL-based hierarchical locomotion framework combining adaptive bipedal walking and quadrupedal crawling for scalable confined-space traversal, with sim-to-real validation on Unitree G1 [P.3].
Junhe Water Affairs Co., Ltd. Jun 2025 – Sep 2025
- Industry internship in software engineering (full-stack development and data processing for water-utility systems).
📖 Projects
A simplified map of my research, coursework, and competition builds — every card links to its GitHub repository. Visit github.com/hwy0507 for the full list.
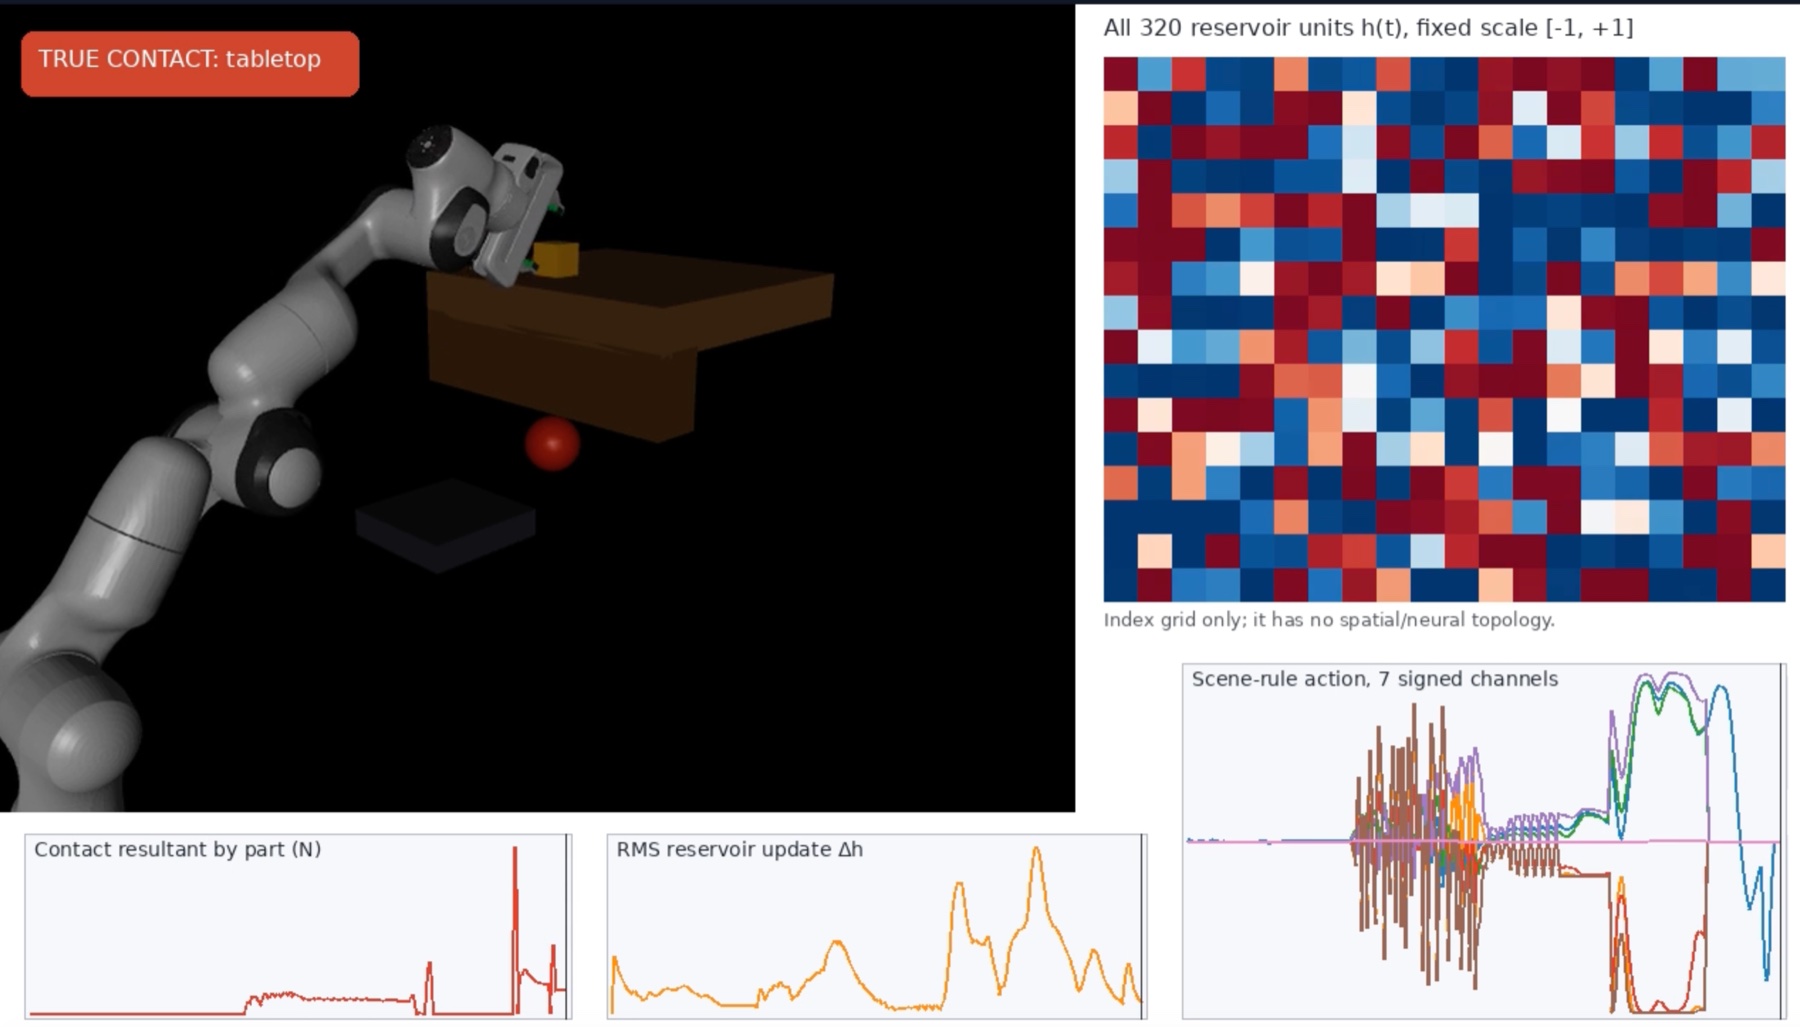
Data-Driven Compliance Control for Franka FR3
Whole-body compliance research in MuJoCo: physics-based 6-D VMC teachers across four contact families, distilled into proprioception-only MLP/ESN policies that yield safely under impacts and smoothly recover trajectories — benchmarked against impedance/admittance baselines on a Pareto frontier.
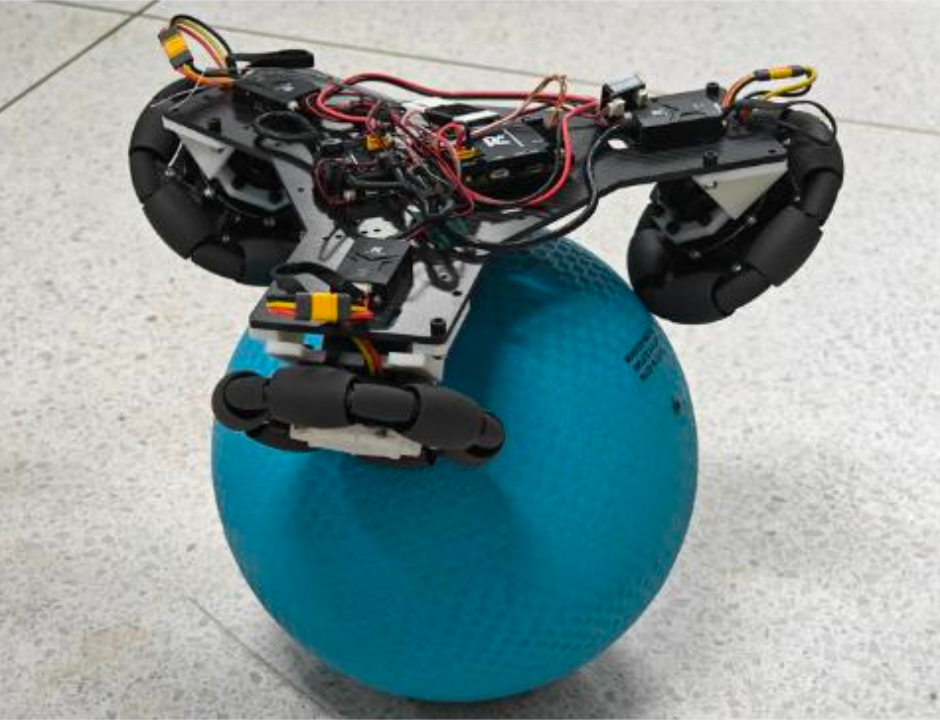
Omnidirectional Spherical-Wheel Satellite Exploration Robot
Core member responsible for the visual system and vision–control integration of a spherical-wheel exploration robot: FAS-based dynamic balance control with IMU–encoder fusion, plus integrated vision perception and planning for autonomous obstacle avoidance in complex terrain.
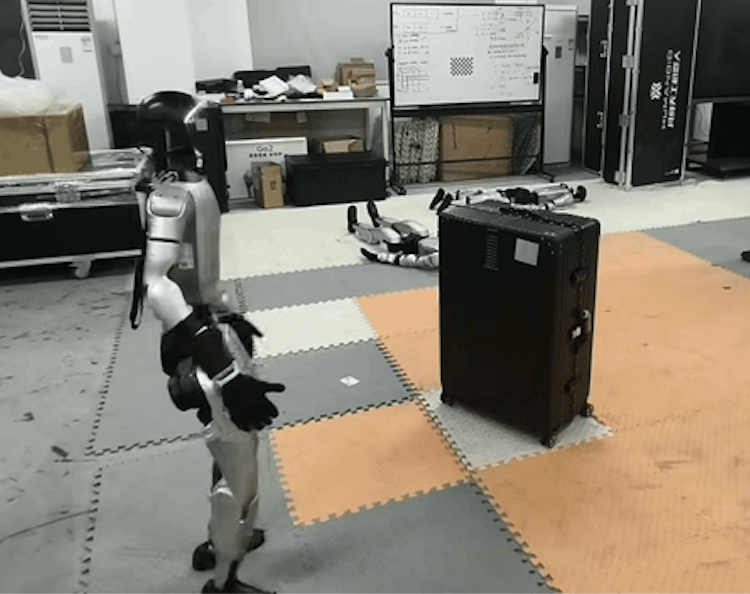
Humanoid Autonomous Navigation on Unitree G1
Full perception–localization–planning–control pipeline deployed on the Unitree G1 humanoid: FAST-LIO LiDAR-inertial odometry, lifecycle-managed Nav2, and YOLOv8 pedestrian tracking on RealSense for autonomous following with dynamic obstacle avoidance in real-world indoor scenes.
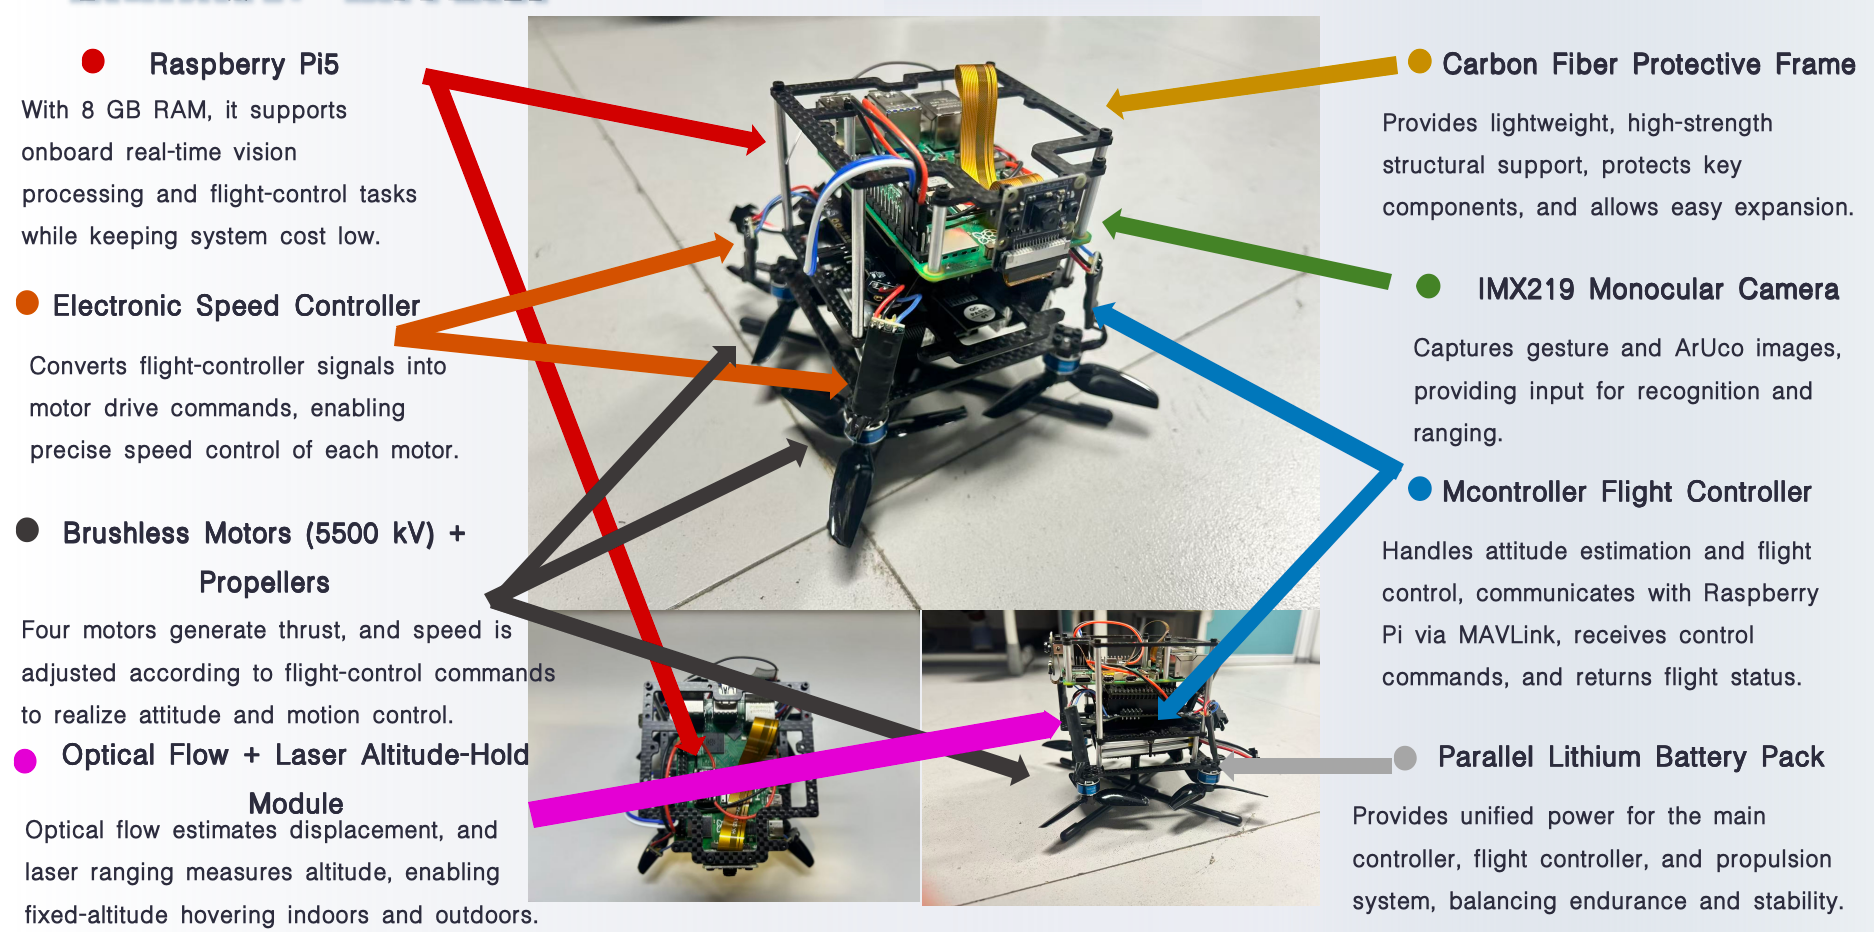
Intelligent Visual Navigation UAV for Fire Rescue
Closed-loop UAV reconnaissance system on Raspberry Pi 5 + Picamera2: MediaPipe gesture triggering, ArUco monocular ranging with distortion calibration, EasyOCR digit recognition with ROI attention and multi-trial voting, and a MAVLink-style serial link to the flight controller.
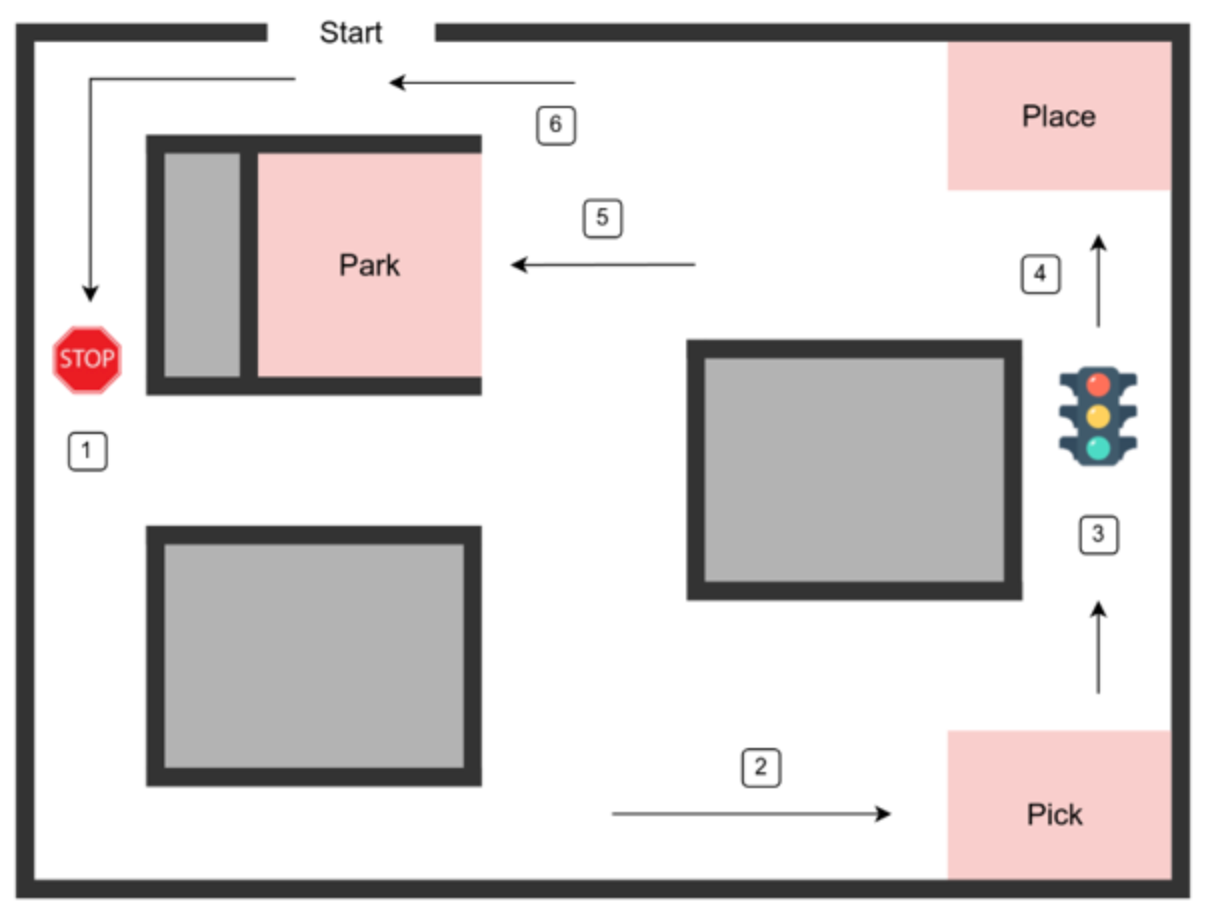
Vision-Guided Mobile Manipulation for Multi-Stage Missions
ROS 2/Nav2 mobile manipulator completing multi-stage missions (stop → pick → traffic-light check → place → park → return) with ArUco visual servoing, IK-based arm control with joint-limit handling, and a distributed finite-state machine — full score on the final contest.
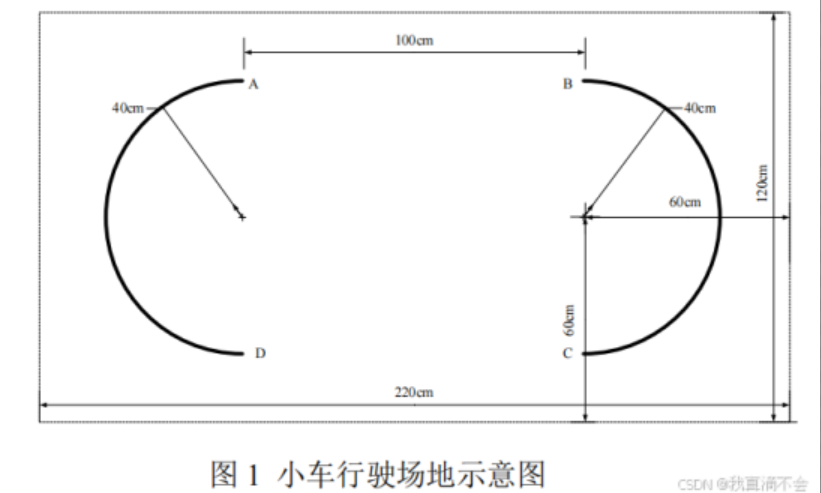
Dual-Board STM32 Line-Following Smart Car
Two-board STM32F103 smart car for the 2024 NUEDC problem H: 7-channel grayscale line following, incremental PID speed control with closed-loop stepper motors (Emm_V5.0 protocol), and an attitude board fusing MPU6050 + HMC5883L via a Mahony complementary filter.
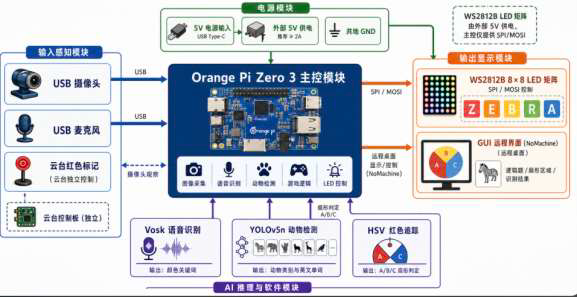
Creature Rescue Protocol: AI Escape Room
Multimodal escape-room game on Orange Pi: offline Chinese ASR (Vosk), a custom YOLOv5n animal detector (17 classes, ONNX edge inference, 88.2% real-world accuracy), pan-tilt red-marker calibration, and an SPI-driven 8×8 WS2812 letter-hint matrix sealing a color + animal password.
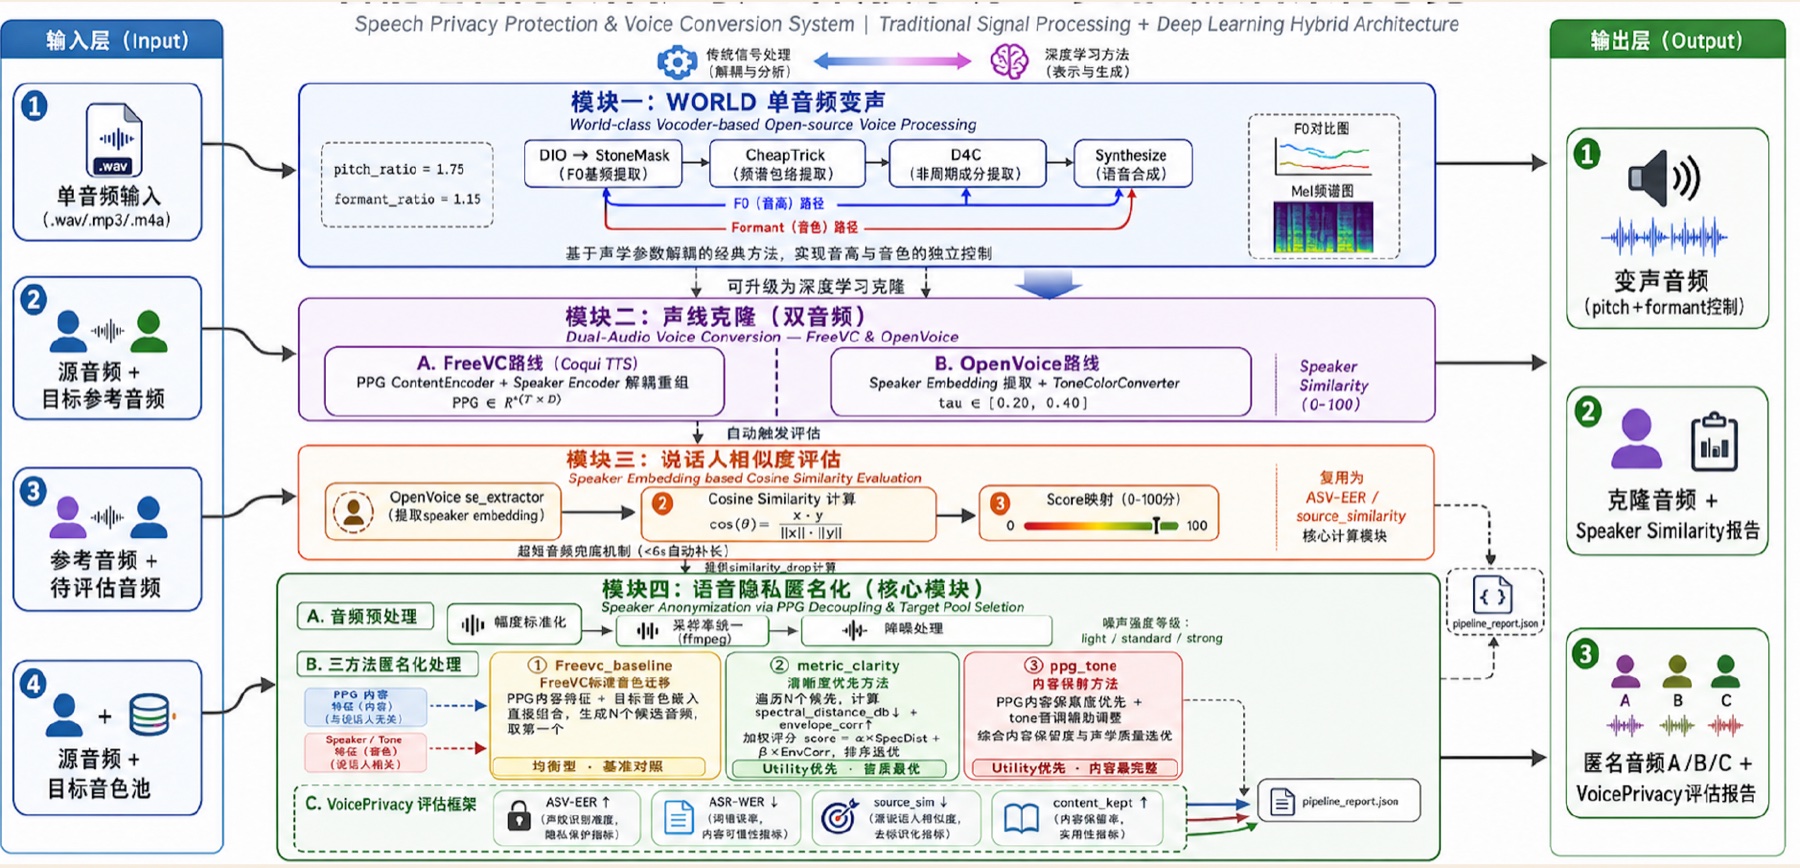
Chinese Speaker Anonymization System
Three-stage voice anonymization pipeline — FreeVC baseline → metric-guided target-pool re-selection → PPG-tone naturalness refinement for Chinese tones — raising ASV EER to 0.583 (near-random) while preserving content, with desktop GUI and web recording demo front-ends.
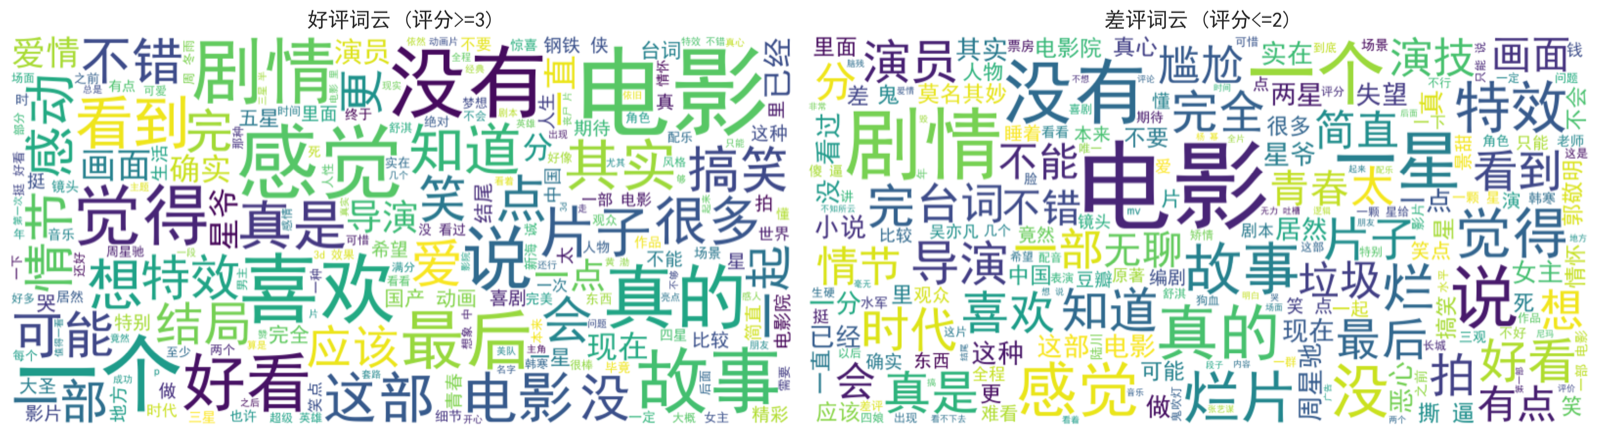
Life-Expectancy Forecasting & Douban Sentiment Analysis
Reproducible supervised-learning pipelines: multi-country life-expectancy regression with KNN imputation and model benchmarking (best XGBoost R² 0.9586), and Douban-review sentiment analysis across TF-IDF / Word2Vec / BERT features, Qwen/GLM prompting, and LLaMA-Factory LoRA fine-tuning.
2048 Merge Game with Monte-Carlo AI
Java Swing 2048-style game (~3.2k lines, clean MVC): four modes (classic / prop / obstacle / time-limit), customizable 2–12 grid, undo stack, a persistent user system with leaderboard, and an asynchronous Monte-Carlo rollout AI auto-player.
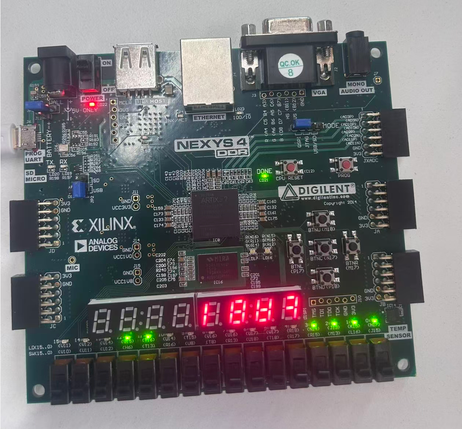
Five-Stage Pipelined RISC CPU on FPGA
RV32I-style five-stage pipelined 32-bit CPU in VHDL on a Digilent Nexys A7: full hazard handling (data forwarding, load-use stall, branch flush), UART-triggered debug readback with on-board CPI counters — 78.57 peak MIPS at 100 MHz, timing-clean (WNS 0.569 ns).
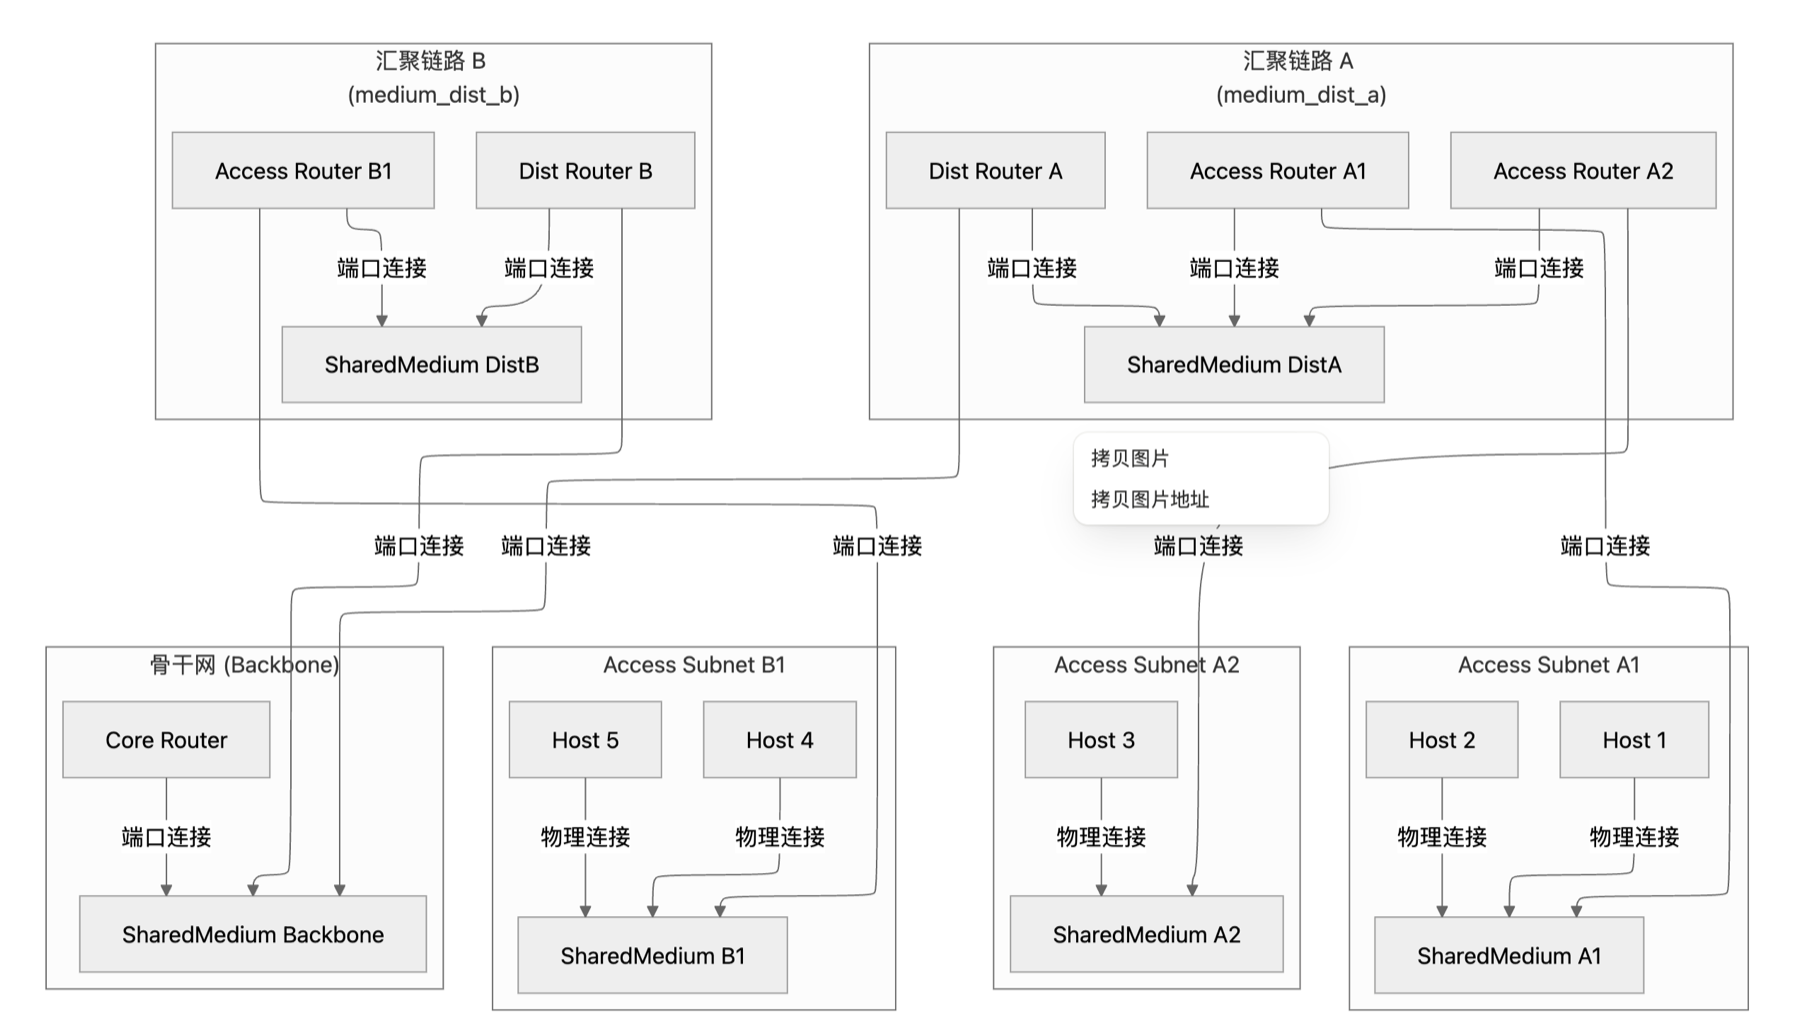
Full-Stack Network Simulator & WeChat-style IM
Layered communication stack built from scratch: physical medium with attenuation/noise, framing, hierarchical routing, and a wireless variant — topped by a custom CHAT/1.0 protocol over TCP with Tkinter GUI, ARQ reliability, and a MIMO + SVD beamforming extension (+7–8 dB gain).
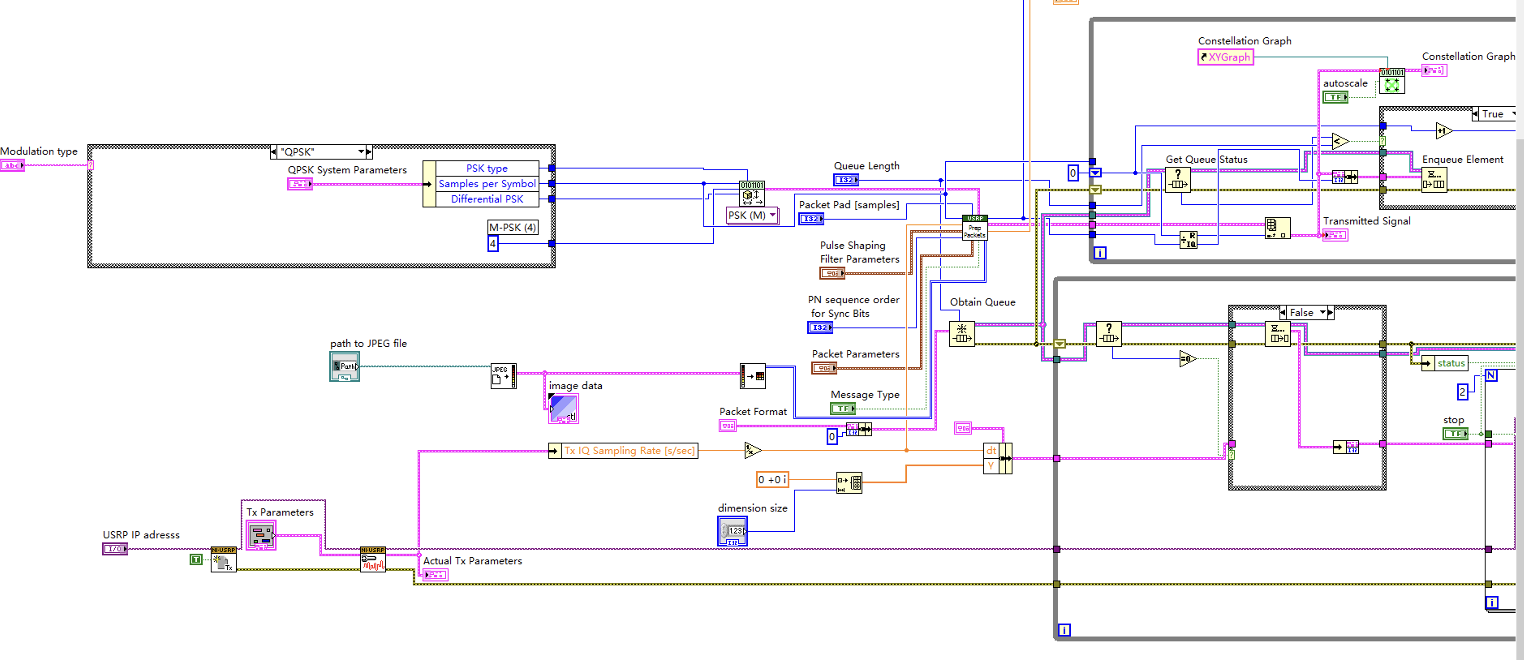
Communication Principles Labs: AM / FM / PSK / SDR
Six labs spanning analog modulation measurements (AM/FM), PSK text-transmission link simulation, and over-the-air software-defined-radio text transceivers — documented in five fully illustrated reports with waveforms, spectra, and link performance.
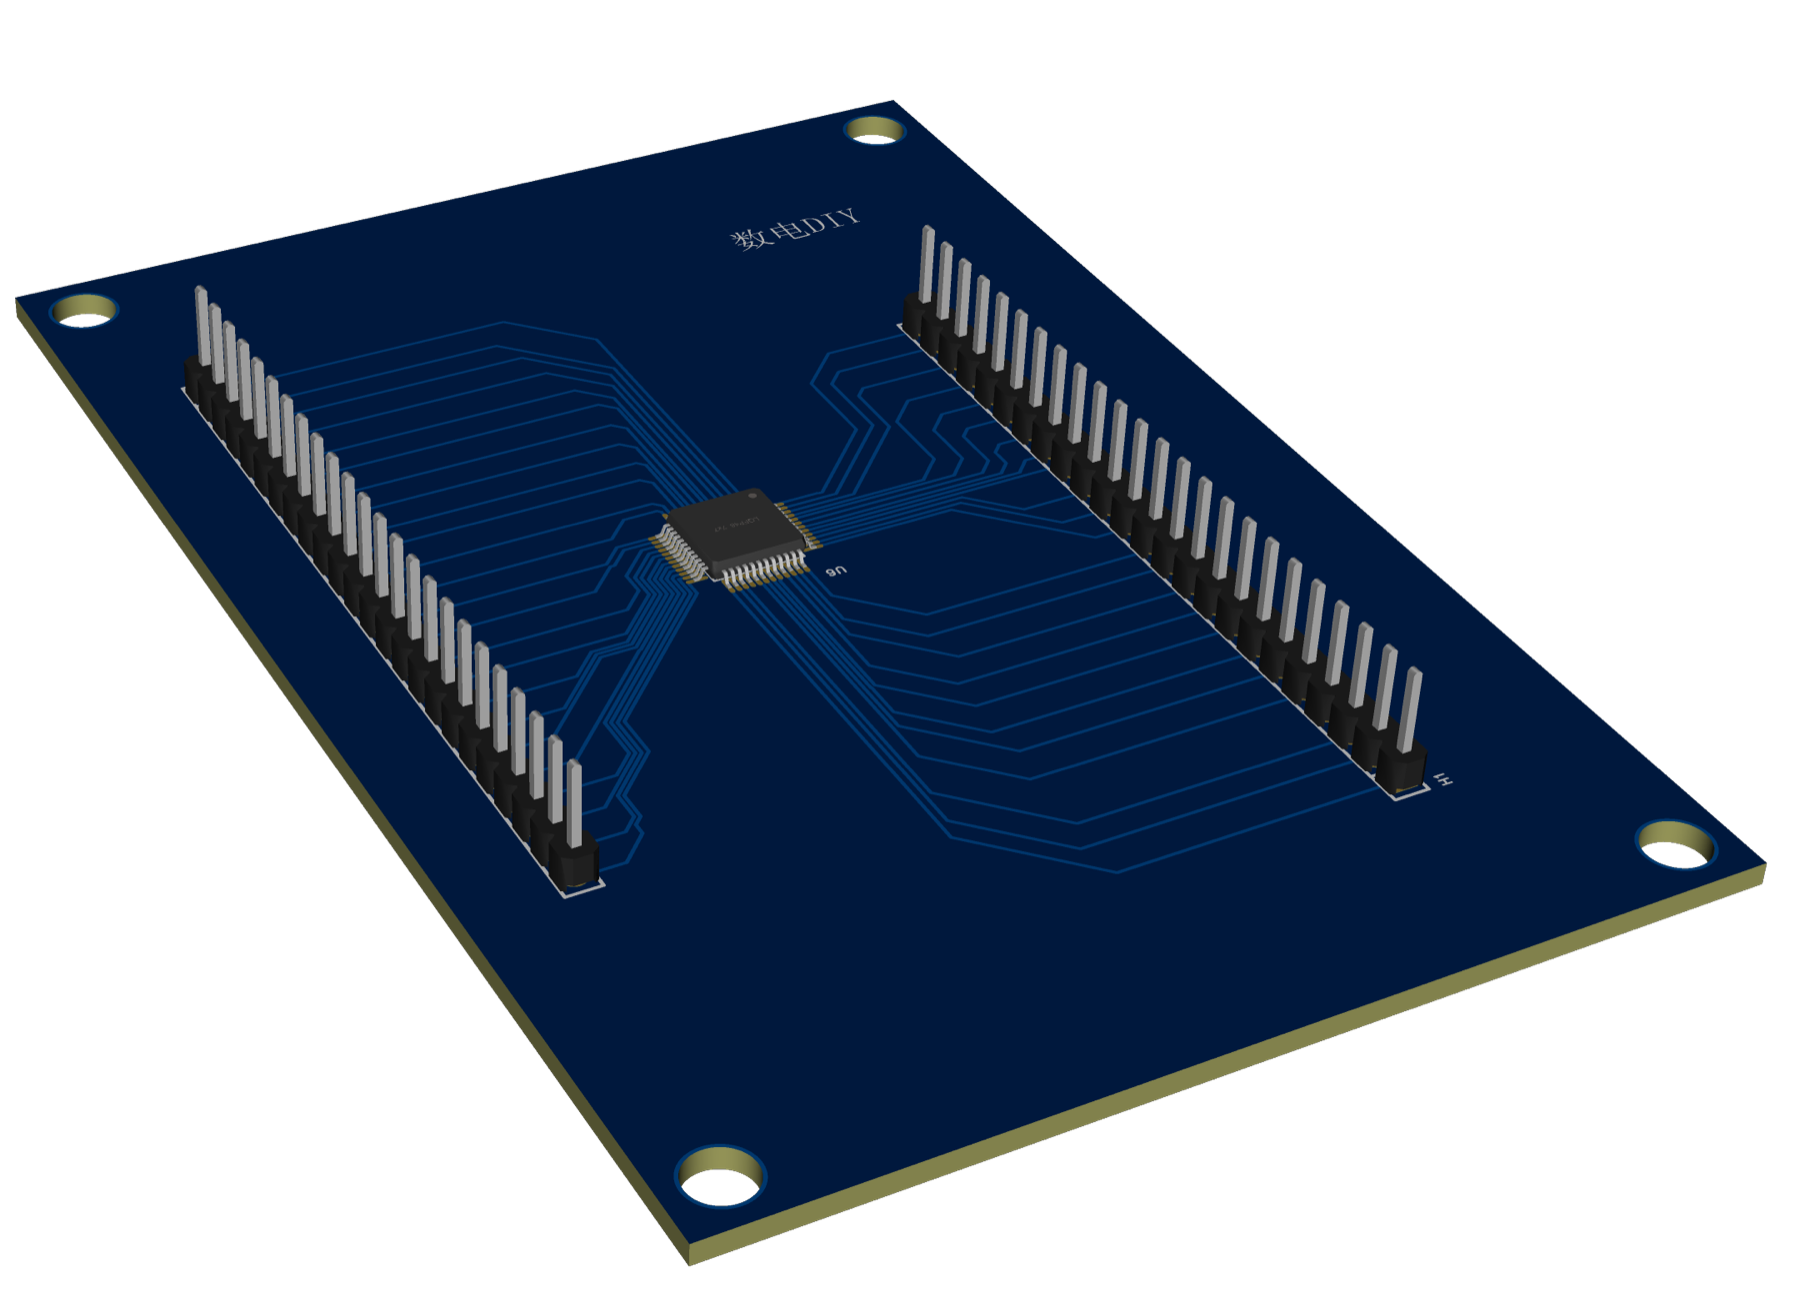
STM32 Current/Voltage Meter — Full PCB Project
Complete PCB project in LCEDA (EasyEDA Pro): schematic capture, LQFP-footprint routing with DRC verification and 3D preview, and a hand-soldered STM32F103C8T6 meter — plus five structured lab reports covering gate logic, CMOS, flip-flops, and sequential circuits.
🏆 Honors and Awards
- National Innovation and Entrepreneurship Training Program — national-level project, core member — 2026
- SUSTech Outstanding Student Model Award (Top 7 / 5000+) — 2025
- Shokz Cup Global Undergraduate Engineering Practice Competition — Platinum Award (1st Place) — 2025
- SUSTech First-Class Scholarship — 2024–2026
- Challenge Cup — Guangdong Gold Award, National Bronze Award — 2024
- China College Students’ Innovation Competition — Guangdong Gold Award, National Bronze Award — 2024
- SUSTech President’s Special Scholarship for Freshmen - 2023